I’m a 3rd-year M.Phil. student in Electronic and Information Engineering at SIGS, Tsinghua University(THU), supervised by Prof. Lu Fang and Prof. Ruiqi Huang. Prior to that, I spent wonderful 4 years at Southeast University(SEU), advised by Prof. Yangang Wang and obtained my bachelor’s degree in 2022.
My research interests mainly lie in 2D and 3D computer vision, especially in:
- Visual Cognition: Human-centric Visual Analysis in Complex Scenes with Gigapixel Resolution.
- Embodied AI: Perceive, Comprehend, and Interact with the Environment through Physical Entities.
🔥 News
- 2024.03: 🎉🎉 Our paper DynamicTrack is accepted by ICME 2024!
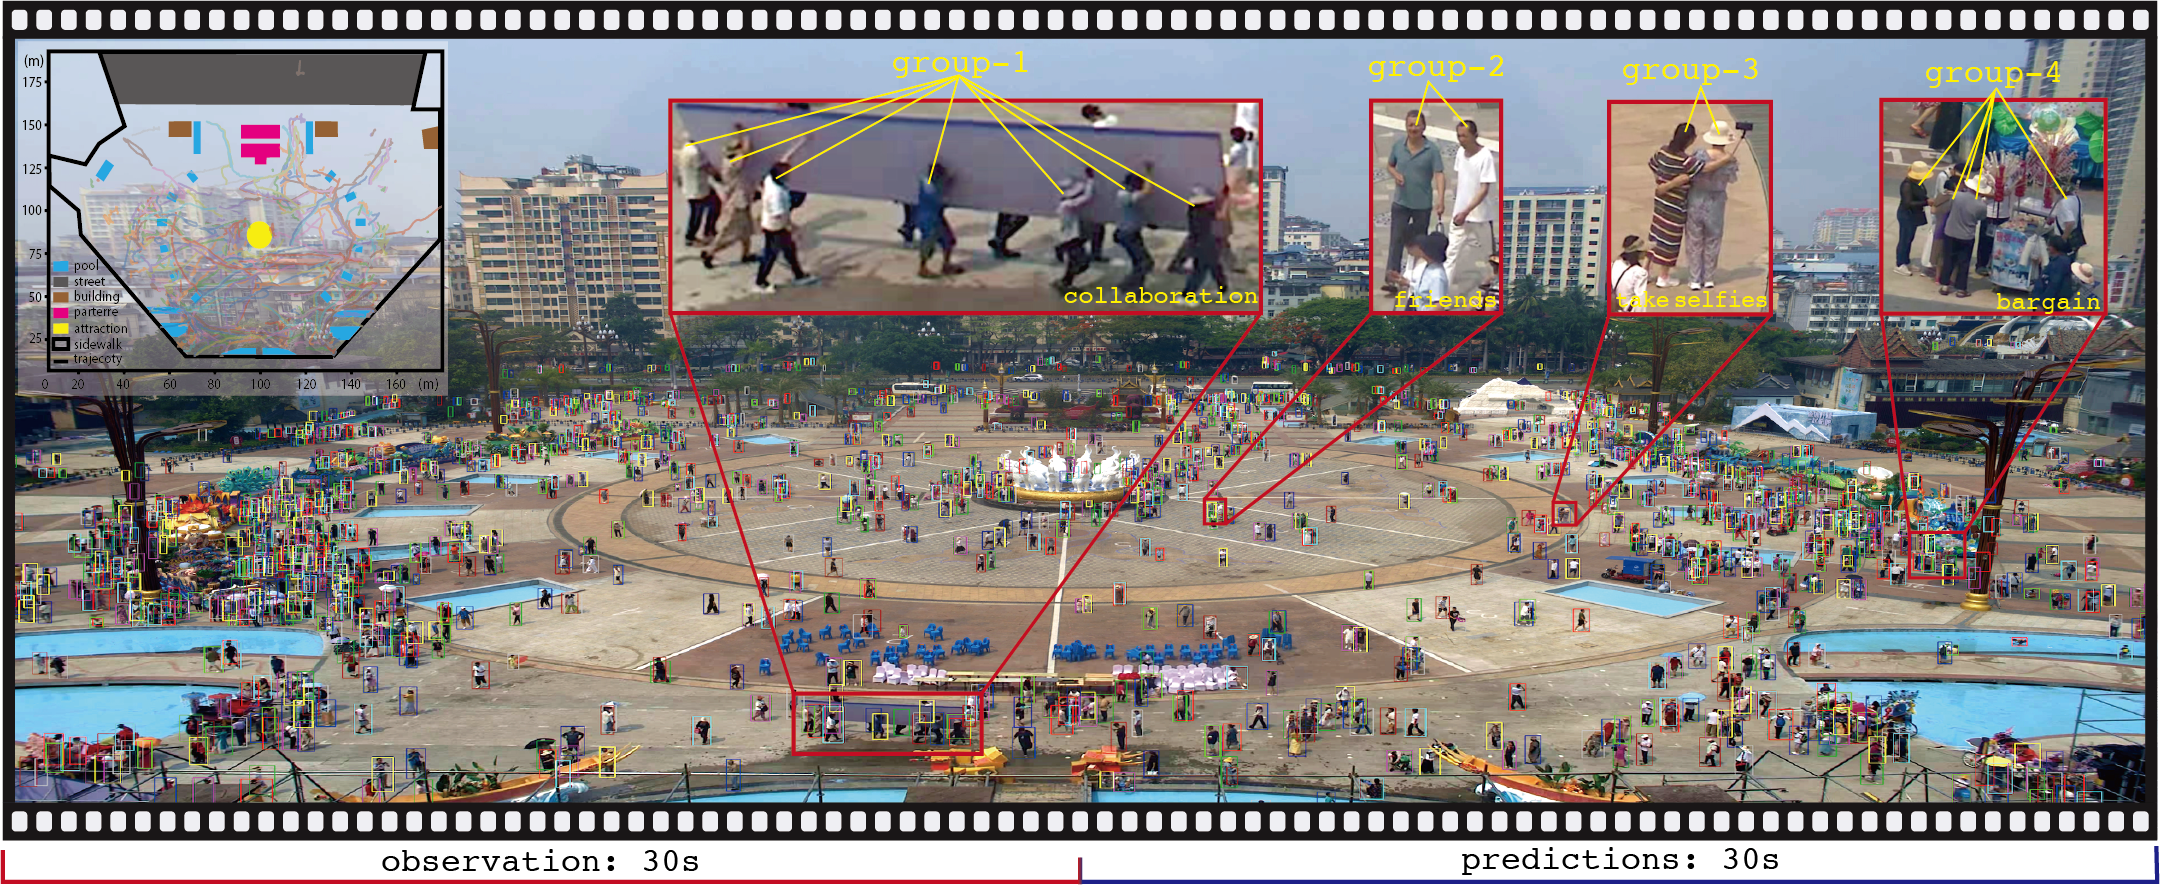
- 2024.02: 🎉🎉 Our paper GigaTraj is accepted by CVPR 2024!
📖 Educations
- 2022.08 - 2025.06, M.Sc. in Electronic Information Engineering, Tsinghua University (THU), Beijing, China.
- 2018.08 - 2022.06, B.Sc. in Automation, Southeast University (SEU), Nanjing, China.
📝 Publications
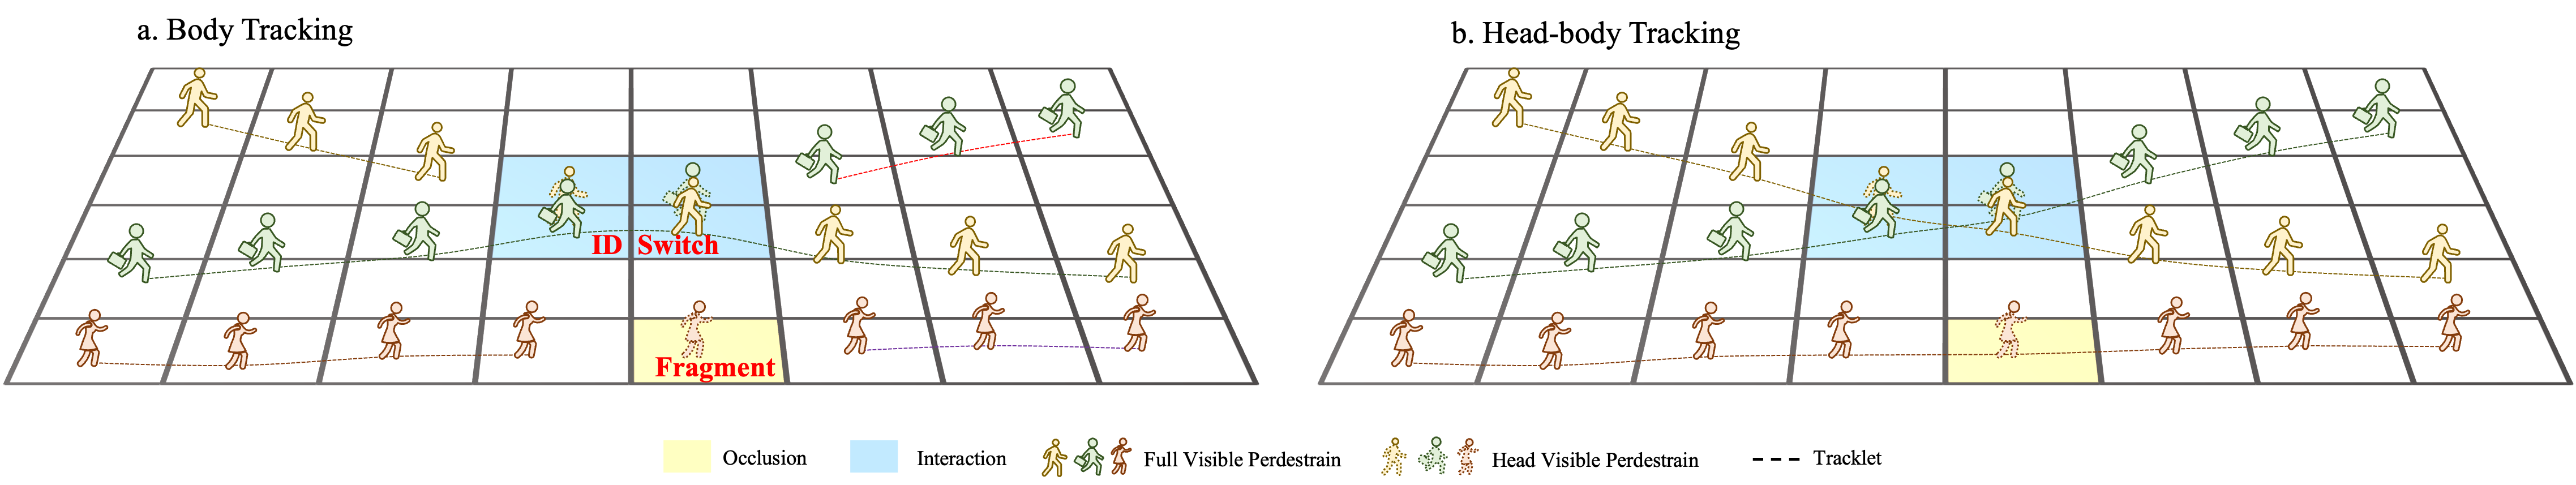
DynamicTrack: Advancing Gigapixel Tracking in Crowded Scenes
Yunqi Zhao*, Yuchen Guo*, Zheng Cao, Kai Ni, Ruqi Huang, Fu Fang†
The IEEE International Conference on Multimedia & Expo (ICME), 2024.
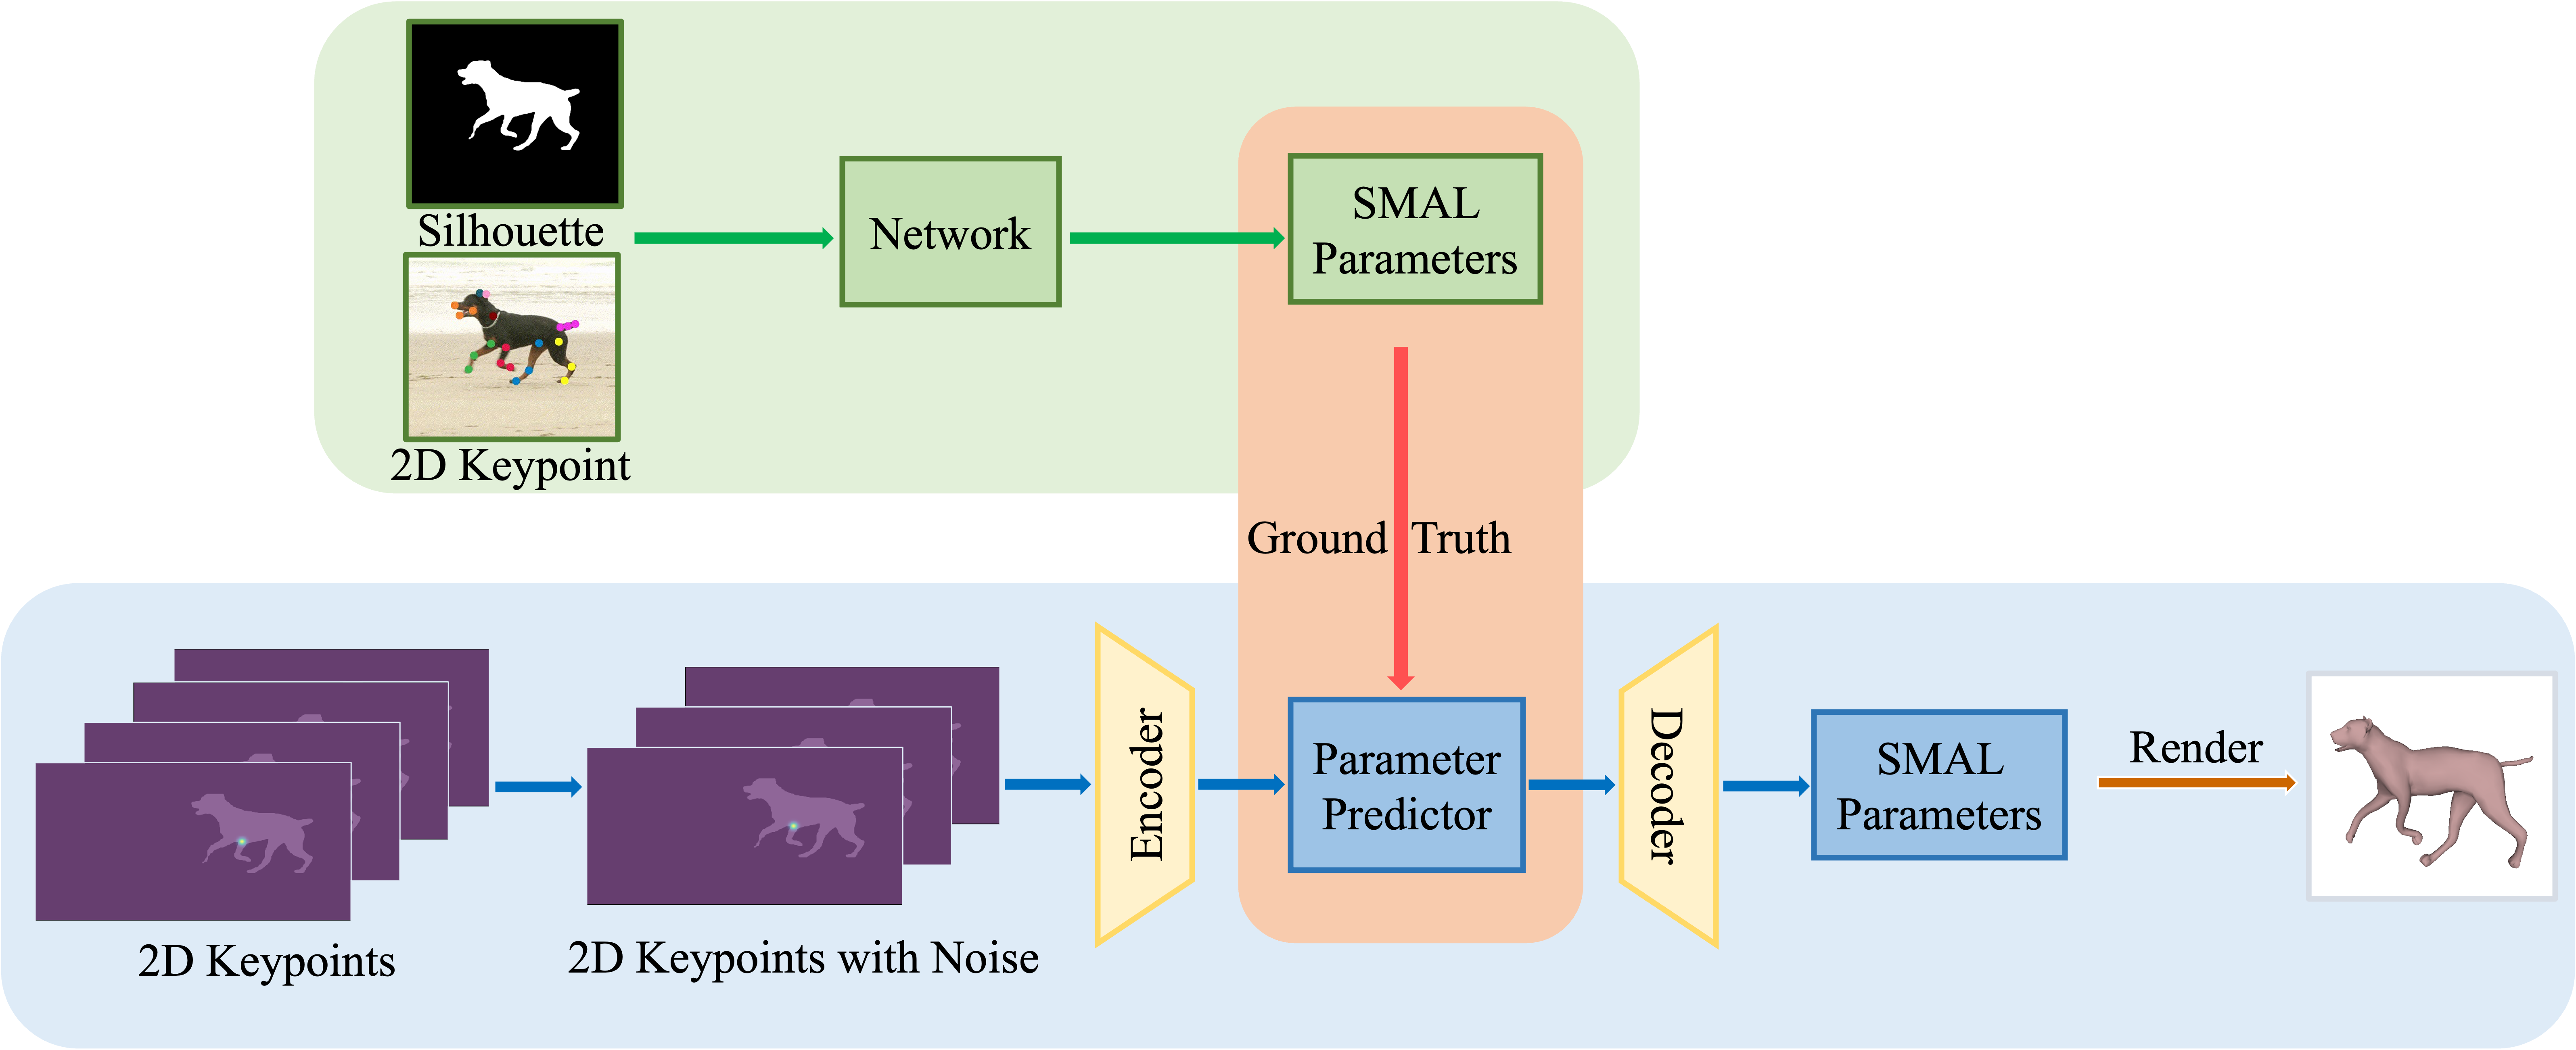
Occluded Animal Shape and Pose Estimation from a Single Color Image
Yiming Xie, Yunqi Zhao, Shijian Jiang, Jiangyong Hu, Yangang Wang†
International Conference on Image and Graphics, (ICIG), 2021.
🎖 Honors and Awards
- 2022, Excellent Graduate, Southeast University.
- 2021, Outstanding students, Southeast University.
- 2019, 2020, National Encouragement Scholarship, the Minister of Education, China.
🖥️ Research Experiences
-
Pedestrian Trajectory Prediction in Gigapixel Complex Scenes 2023.07 – 2024.11
Propose a trajectory prediction dataset featuring hundreds of pedestrians in gigapixel complex scenes.
Generate pedestrian trajectories, conduct data annotation, and perform statistical analysis.
Mentor: Prof. Lu Fang -
Multi-object Tracking in Gigapixel Complex Scenes 2022.09 – 2023.06
Propose a contrastive learning-based detector for simultaneous head and body detection.
Design a hierarchical association algorithm to utilize head and body cues for multi-object tracking.
Mentor: Prof. Lu Fang and Prof. Ruqi Huang
💡 Projects
-
Interactive General Object Grasping (Internship Program) 2024.04 – 2024.07
Develop an interactive general object grasping system for robotic applications in open-world.
Employ SAM for interactive target localization and GraspNet for general object grasping.
-
Scene Reconstruction and Understanding for Intelligent Interaction (B.S. Thesis) 2021.11 – 2022.08
Design a real-time system for indoor scene reconstruction, segmentation, and simplification.
Develop local and global interaction patterns to improve 3D perception for visually impaired people.
-
3D Reconstruction of Animals from Single Color Images 2020.10 - 2021.05
Employ a parametric model SMAL for 3D reconstruction of animals from a single color image.
Predict the shape and pose parameters using the skeletal and contour information of animals.